2026-07-29
Avionics & AI Part 1: Two-Layer Isolated Architecture & Hardware Trade-Off
Back to All Logs
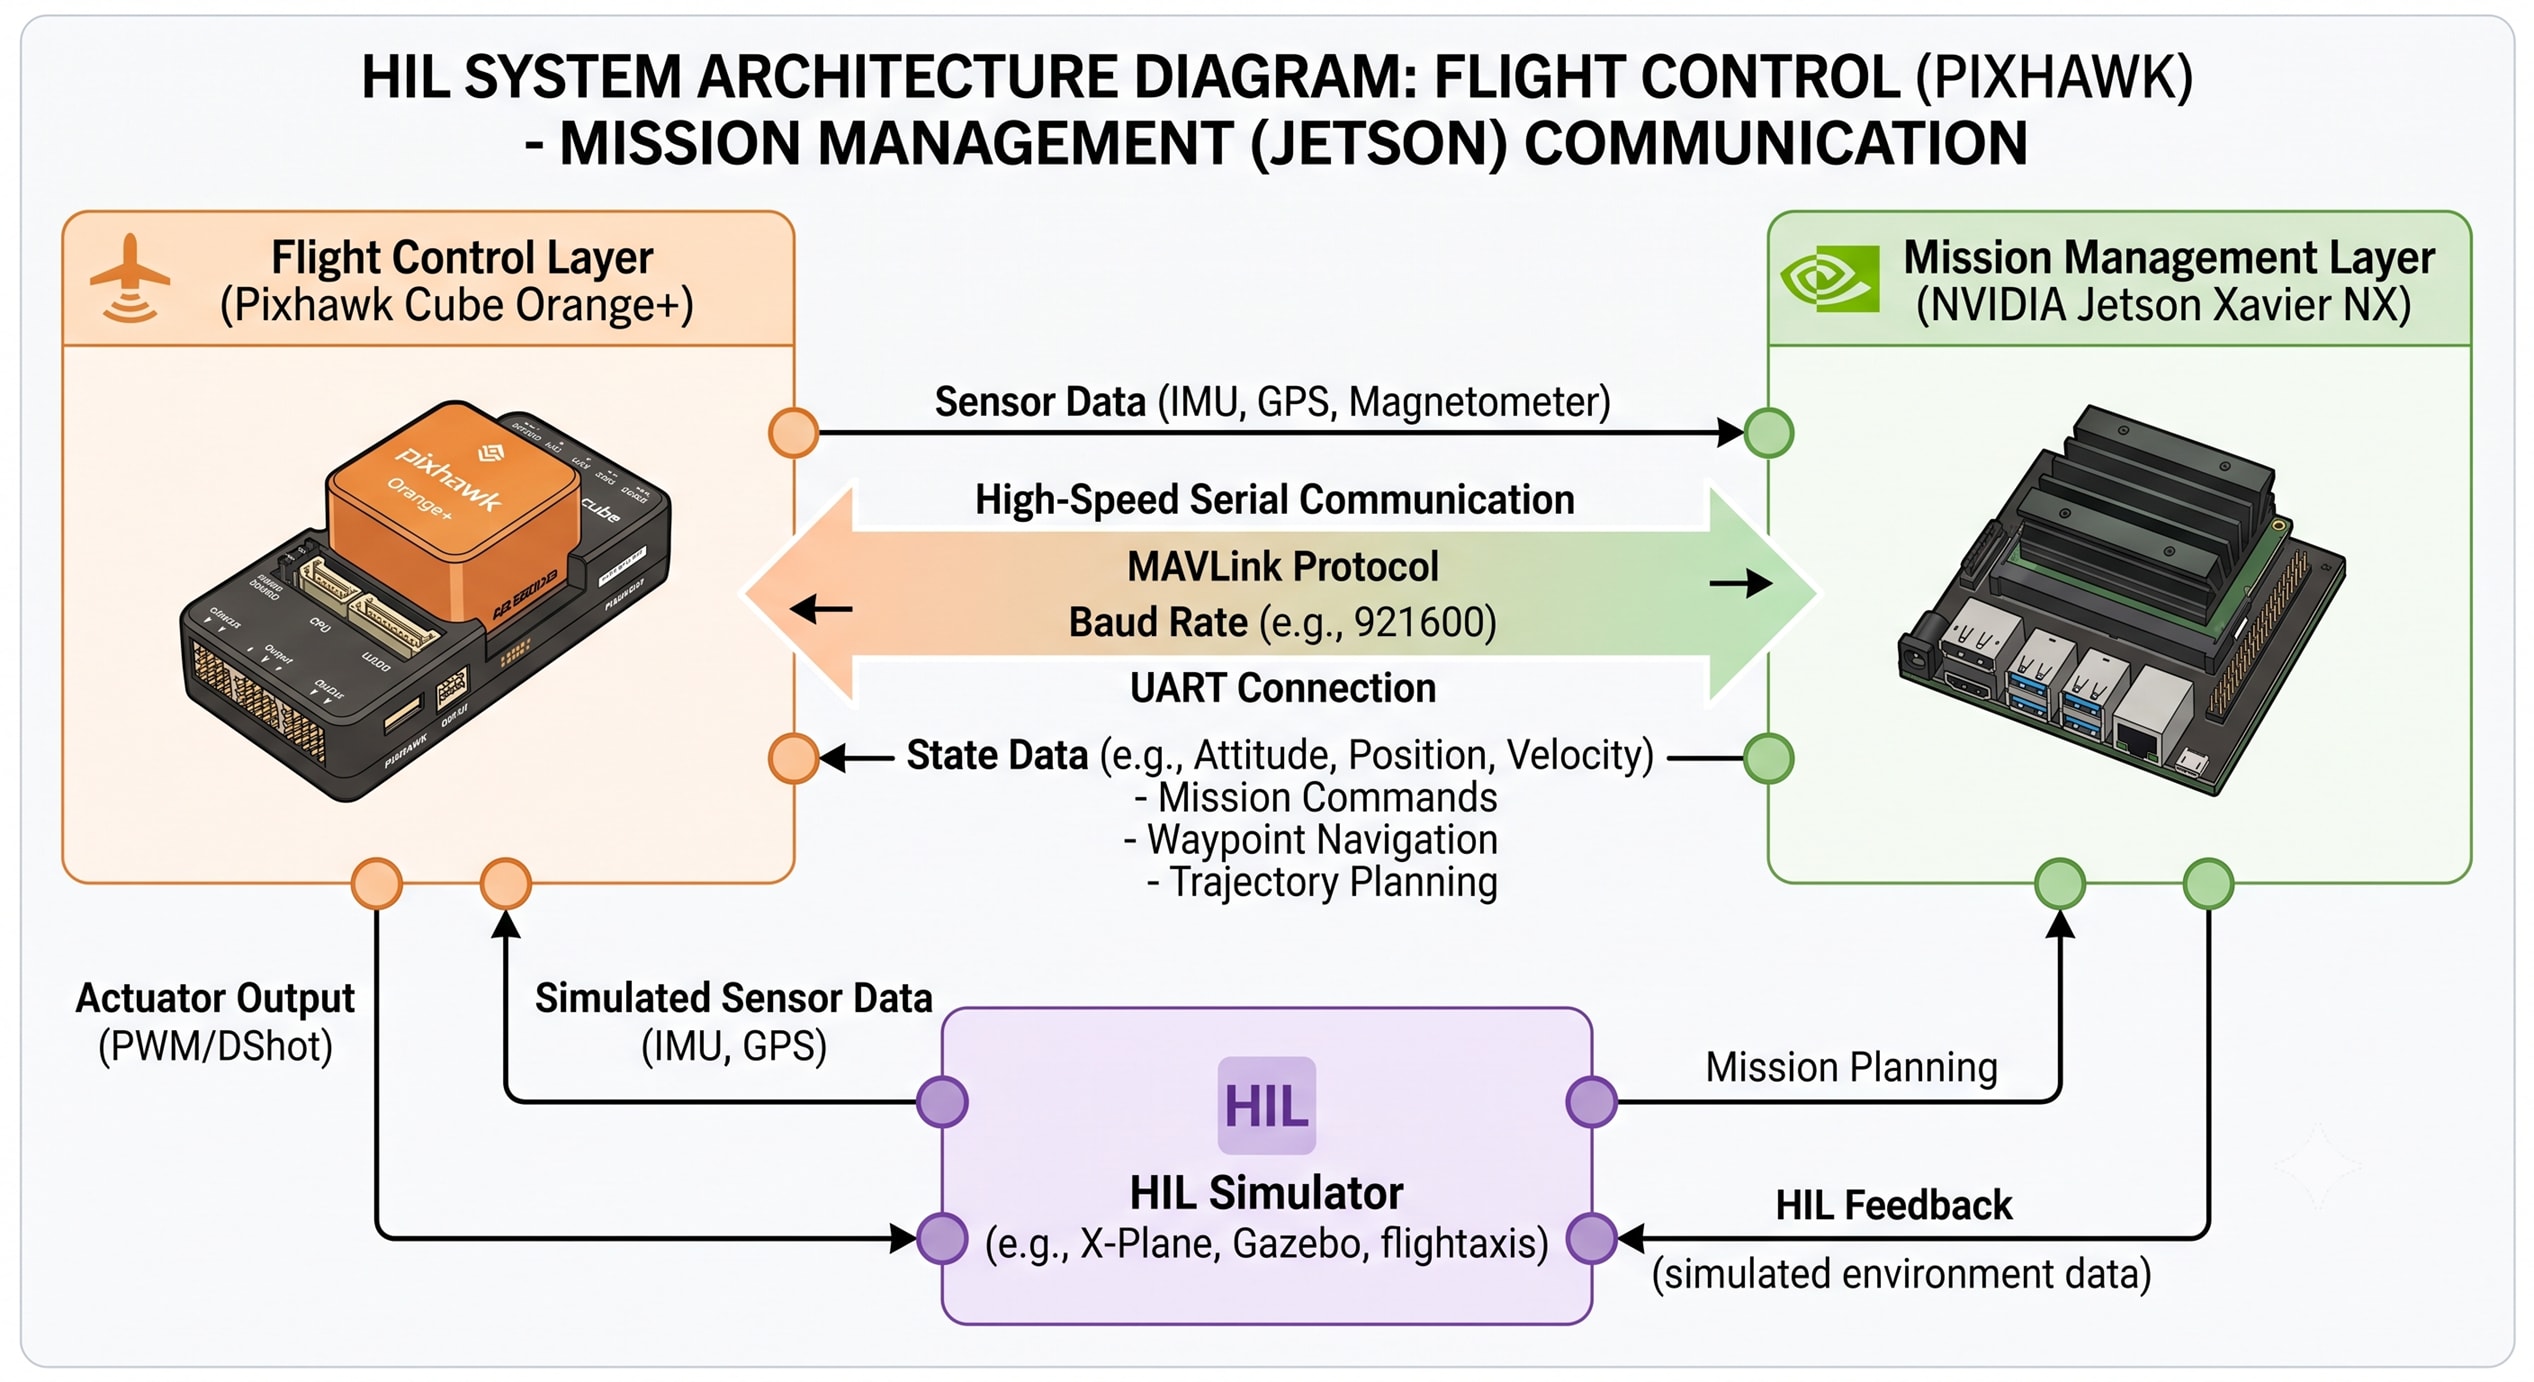
The Flight Control Layer (Pixhawk Cube Orange+ / ArduPilot) is hardware-isolated from the Mission Management Layer. Raspberry Pi 5 was evaluated but rejected due to low standalone inference (8-12 FPS) at 12 m/s cruise, 10 FPS latency causes a 1.2 m position blind spot. Trading off mass for the 21 TOPS NVIDIA Jetson Xavier NX increased processing to 30-40 FPS (TensorRT FP16), reducing latency error to <0.3 m.